
Title: Safe and Responsible Autonomy for Intelligent Vehicles
Abstract:
Autonomous vehicles must coordinate with other agents, navigate complex environments, and make decisions that are both safe and socially responsible. This talk presents a control-theoretic perspective on these challenges. I first introduce guiding vector fields for flexible platooning and path-following of mobile robots under communication and environmental constraints, with emphasis on singularities, vehicle joining and leaving, and obstacle avoidance. I then discuss how control barrier functions can provide explicit collision-avoidance guarantees, and how transformer-based AI may assist in constructing and adapting symbolic safety certificates for complex driving scenarios. I conclude by briefly outlining ongoing interdisciplinary work on incorporating considerations from liability law into optimization-based vehicle control. Together, these developments point toward intelligent vehicles that can move cooperatively, act safely, and make decisions responsibly.
Biography:
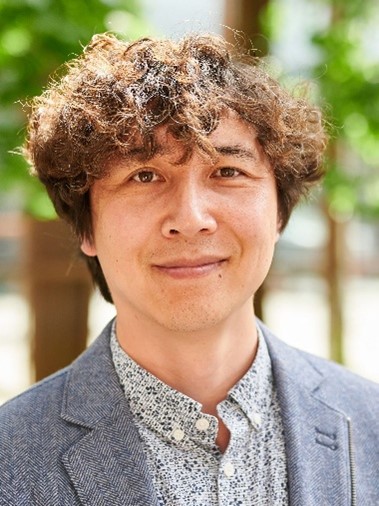
Ming Cao has since 2016 been a professor of networks and robotics with the Engineering and Technology Institute (ENTEG) at the University of Groningen, the Netherlands, where he started as an assistant professor in 2008. Since 2022 he is the director of the Jantina Tammes School of Digital Society, Technology and AI at the same university. He received the Bachelor degree in 1999 and the Master degree in 2002 from Tsinghua University, China, and the Ph.D. degree in 2007 from Yale University, USA. From 2007 to 2008, he was a Research Associate at Princeton University, USA. He worked as a research intern in 2006 at the IBM T. J. Watson Research Center, USA.
He is an IEEE Fellow and a distinguished lecturer of the IEEE Control Systems Society. He is the 2017 and inaugural recipient of the Manfred Thoma medal from the International Federation of Automatic Control (IFAC) and the 2016 recipient of the European Control Award sponsored by the European Control Association (EUCA). He is a Senior Editor for Systems and Control Letters, and is or has been an Associate Editor for IEEE Transactions on Automatic Control, IEEE Transaction on Control of Network Systems, IEEE Transactions on Neural Networks and Learning Systems, IEEE Transactions on Circuits and Systems, IEEE Robotics & Automation Magazine, and IEEE Circuits and Systems Magazine. He is a member of the IFAC Council. He is the General Chair of IFAC World Congress in 2029 in Amsterdam. His research interests include autonomous robots and multi-agent systems, complex networks and decision-making processes.

Copyright © 2026 The 10th CAA International Conference on Vehicular Control and Intelligence (CVCI2026)