
Title: Short-horizon predictive control – a general approach to the control of vehicle dynamics, from low-speed kinematic control to high-speed limit handling.
Abstract:
Short-horizon predictive control is investigated within an Artificial Flow Guidance (AFG)-based Unified Co-Pilot architecture. In this framework, high-level motion objectives, including reference paths, speed targets, and motion boundaries, are translated via an intermediate AFG-layer into a spatially distributed velocity vector field, giving direct motion guidance for chassis control. AFG may utilize two guide points (on a rigid vehicle) to provide a synchronized motion reference for direction, speed and yaw velocity. After briefly outlining methods for AFG computation, examples are presented for motion control under three different control regimes: (a) directional (kinematic) control at low speed, (b) model-predictive control under dynamic conditions, and (c) high-speed control near the vehicle handling limits. Results are from both high-fidelity simulation and real-world testing are presented.
Biography:
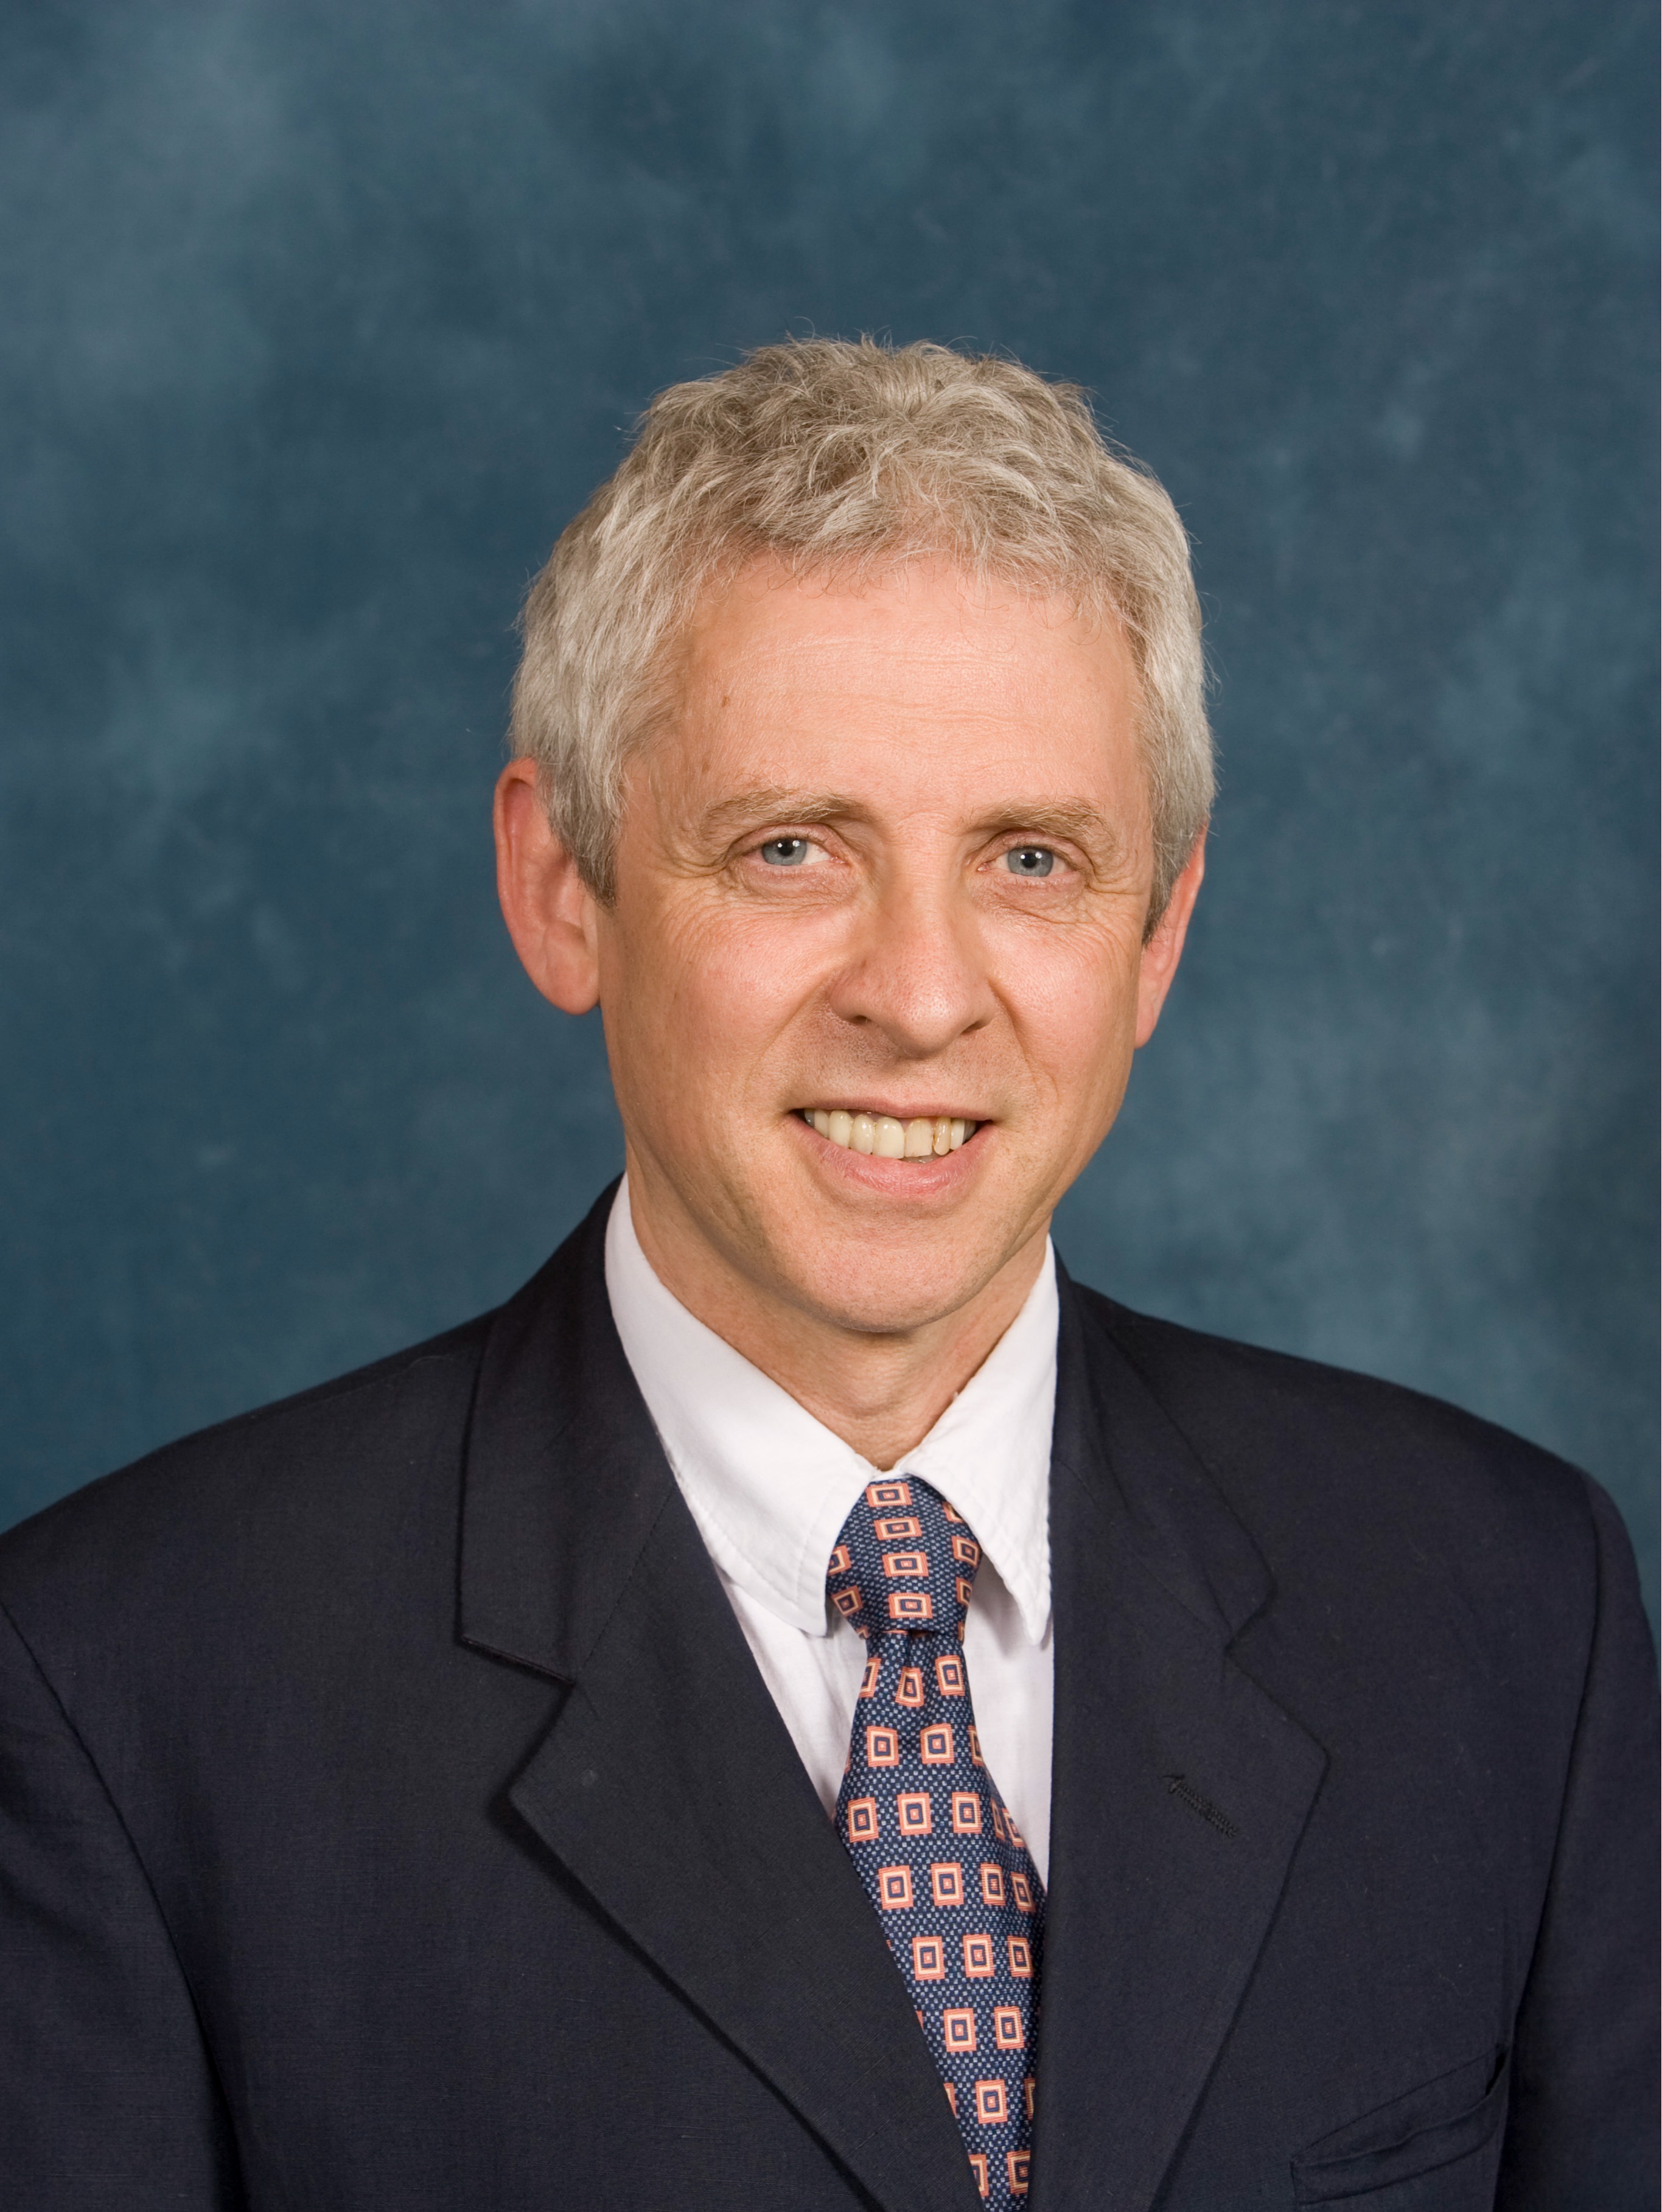
Prof. Timothy James Gordon is Professor of Vehicle Control Engineering in the School of Engineering and Physical Sciences at the University of Lincoln, UK. He joined Lincoln in 2014 after ten years at the University of Michigan, where he was Professor of Mechanical Engineering and led the Engineering Research Division at the Transportation Research Institute. He previously held the Ford Professorship at Loughborough University and has worked extensively with the automotive industry. His research focuses on vehicle dynamics and control, active safety, collision avoidance, driver modelling, safety system evaluation, and autonomous vehicle guidance, including vehicle control up to the limits of road-surface friction. He is President of the International Association for Vehicle System Dynamics.

Copyright © 2026 The 10th CAA International Conference on Vehicular Control and Intelligence (CVCI2026)