
Title: Learning-based Optimal Control for Intelligent Unmanned Systems
Abstract:
This talk analyzed the research challenges in optimal control problems for unmanned systems and intelligent vehicles, which include model nonlinearities, uncertainties, and dynamics variations. The difficulties in existing model predictive control and learning control methods are also investigated. Then, some recent advances in learning-based optimal control methods are introduced, which include end-to-end deep reinforcement learning, multi-task pre-training, optimal control with Koopman-based model learning and online policy transfer, learning-based predictive control for single agent and multiple agents. The applications of the above methods in unmanned systems and intelligent vehicles are also demonstrated. At last, the directions for future works are also analyzed.
Biography:
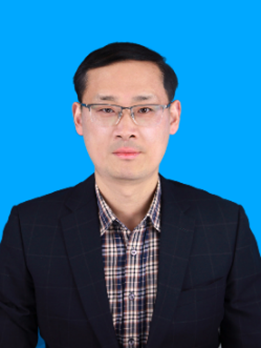
Prof. Xu is a full Professor at the College of Intelligence Science and Technology, National University of Defense Technology. He is a recipient of the National Science Fund for Distinguished Young Scholars, and the leader of a National Natural Science Foundation's Innovative Research Group. His research areas include autonomous control and machine learning for intelligent unmanned systems. He is one of the main recipients for one National Natural Science Second Prize, two Hunan Provincial Natural Science First Prizes, one Hunan Provincial Scientific and Technological Innovation Team Award, and one Wu Wenjun Artificial Intelligence Science and Technology Award (Natural Science Category). He served as the Deputy Director of the Adaptive Dynamic Programming and Reinforcement Learning Committee of the Chinese Association of Automation, Deputy Director of the Parallel Control and Management Committee, and Advisory Committee Member of the Robotics Intelligence Committee. He has published three monographs and over 150 SCI-indexed papers in journals such as Nature Communications, IEEE TPAMI, and IEEE TNNLS, earning a spot among the world's top 2% scientists with the highest lifetime impact. He has served as the Associate Editor for IEEE Transactions on SMC: Systems, Information Sciences, International Journal of Robotics and Automation, among others, as well as Deputy Editor-in-Chief of CAAI Transactions on Intelligence Technology and an Editorial Board Member of Control Theory and Applications.

Copyright © 2026 The 10th CAA International Conference on Vehicular Control and Intelligence (CVCI2026)